企业概览
围绕企业资料展示真实经营信息
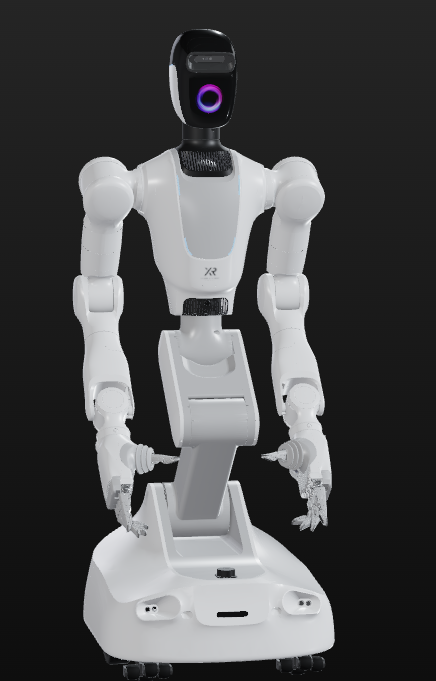
A pair of co-designed, three-finger, nine-DoF dexterous manipulation interface: one wearable for data collection, one for robot deployment.A generative world model for action-controllable, long-horizon robotic simulation. Built on next-scale autoregression with scale-compressed streaming memory and on-policy alignment, it generates visual futures in a coarse-to-fine manner, achieving calibrated task outcomes and consistent policy rankings across 600+ matched sim-to-real closed-loop rollouts.Human-to-robot One-Shot Skill Acquisition (HOST)A training-free framework that enables robots to acquire new manipulation skills in seconds from a single human video while retaining previously mastered capabilities.A multimodal action tokenizer that doubles as a semantic interface between vision-language reasoning and continuous robot control.XRZero-G0 is an embodied data acquisition and strategy learning system designed through deep collaboration between hardware and software. It aims to overcom...
企业频道
从资料、产品、动态到联系方式
根据该企业已开通的会员频道自动展示入口,方便访客快速进入对应内容。